Loading CAD geometry

Mladen Uzunov / Network engineer & ASEC MSc student

Engineering
across the
full stack

I work on production networks at Digitas and study Aerospace Engineering and Communications at Sofia University.

Explore the work ↓View CV

SCARA diploma project / 2026

From first sketch
to motion

Fusion 360 and a printed structure, four stepper drives, inverse kinematics running on an ESP32, and a Modbus contract with a Siemens PLC.

Siemens PLCModbus TCPESP32-S34-axis motion

Defence result / July 2026

Excellent
6.00 / 6.00

Built and defended end to end: the mechanics, the firmware, and the industrial control layer between them.

Open the case study ↗

SCARA diploma project

270 mm of reach,
€232 of parts.

A three-axis SCARA with a motorised gripper, running the same control pattern as an industrial cell at a scale that fits on a desk and a budget a student can actually justify.

Pick-and-place cycle / ESP32 controlView the complete system ↗
270 mmCalculated maximum reach
1–2 mmTypical observed endpoint deviation*
230 gPhysically lifted payload
€232Estimated platform BOM

* Preliminary caliper-based endpoint-return test over 25 cycles with an approximately 100 g payload; not a metrology-grade certification.

Verified

Autonomous pick-and-place under ESP32 control, bidirectional Modbus TCP register exchange, firmware homing and post-fix 25-cycle endpoint-return test.

Designed

Siemens S7-1200 supervisory sequence, 500 g design payload, serviceable printed structure and separated power/control architecture.

Read the engineering case study →

Source releaseThe CAD, the ESP32 firmware and the S7-1200 program are being cleaned up for a public repository. Everything on this page will be reproducible from it. Email me if you want it before then.

Right now

Work and study

Current role

Making the network document itself

Network Engineer at Digitas, on a multi-vendor data-centre estate going through a large switching refresh. I carry the topology diagrams, connection documentation, configuration migration and cut-over, and own RADIUS and SNMP across every device. The part I care about most is NetBox: the estate is documented there end to end, and interfaces, VPNs and tunnels now sync into it on their own.
NetBoxMulti-vendor switchingRADIUS & SNMP

Current studies

Aerospace Engineering and Communications

I'm pursuing an MSc at Sofia University's Faculty of Physics, building on my background in networking and mechatronics.

ASECMSc in progress

Professional history

Six years of keeping
production boring

Linux operations, DevOps automation, enterprise networking. Infrastructure is only visible when it goes wrong, so most of the craft is in making sure it doesn't, and in leaving it documented enough that the next person can see why it works.

  1. 01
    2024 — now

    Network Engineer

    Digitas

    Multi-vendor data-centre networking: switching, edge firewalls, load balancing and CDN/DDoS protection. Supporting a large switching refresh through documentation, configuration migration and cut-over, owning RADIUS and SNMP estate-wide, and running NetBox as the source of truth with automatic interface, VPN and tunnel sync.

    AristaJuniperFortiGateA10NetBoxRADIUSSNMP
  2. 02
    2022 — 2024

    DevOps Engineer

    Digitas

    Built automated patching and deployment workflows for hundreds of virtual machines, hardened delivery through Artifactory and Xray, and wrote tools adopted across teams.

    Ansible AWXPuppetGitLab CIPythonRHELVMware
  3. 03
    2019 — 2022

    Linux System Administrator

    SiteGround

    Operated and troubleshot Linux hosting infrastructure at scale, supported large migrations and turned repetitive diagnostic work into Bash automation.

    LinuxBashWeb infrastructureOperations
Read the full CV ↗

Technical scope

What I actually
work with

Five layers, top to bottom. The right-hand column is the honest part: where each one lives, and where the rack stops and the bench begins.

  1. L5

    Infrastructure

    Linux · RHEL · VMware · Containers · Observability

    Production

  2. L4

    Networks & edge

    Arista · Juniper · FortiGate · A10 · CDN & DDoS · NetBox

    Production

  3. L3

    Automation & software

    Python · Bash · Ansible · Puppet · CI/CD · APIs · MCP

    Both

  4. L2

    Embedded

    ESP32 · Pico · STM32 · Arduino · C/C++ · I²C · SPI · UART

    Bench

  5. L1

    Mechanical

    Fusion 360 · SolidWorks FEA · 3D printing · Motion · Sensors

    Bench

Selected projects

Software, and
things that move

Two tools on PyPI, a handful of university builds, and the UMX prototype that taught me what not to do on the diploma robot.

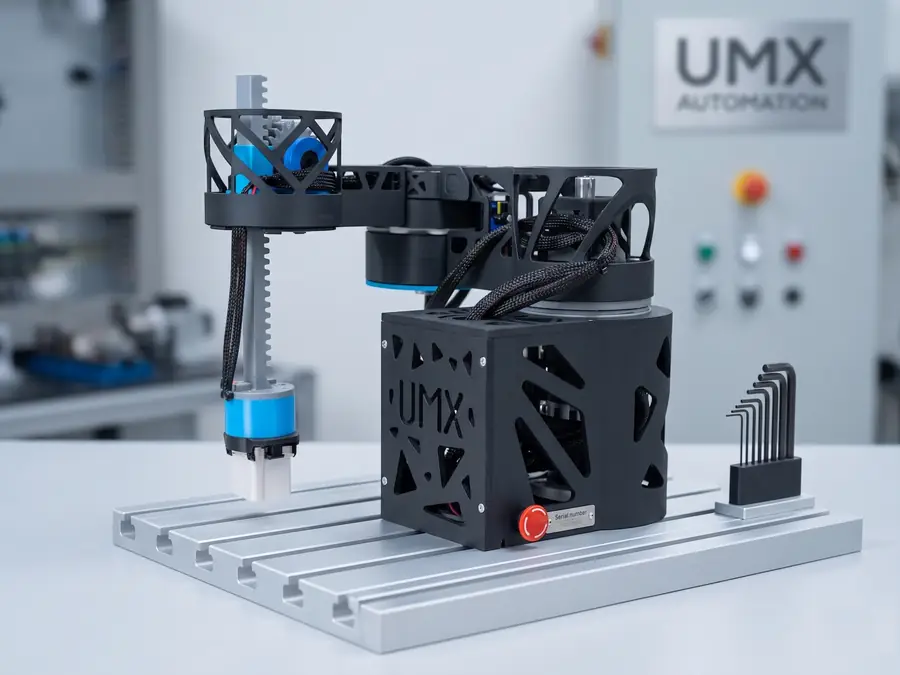
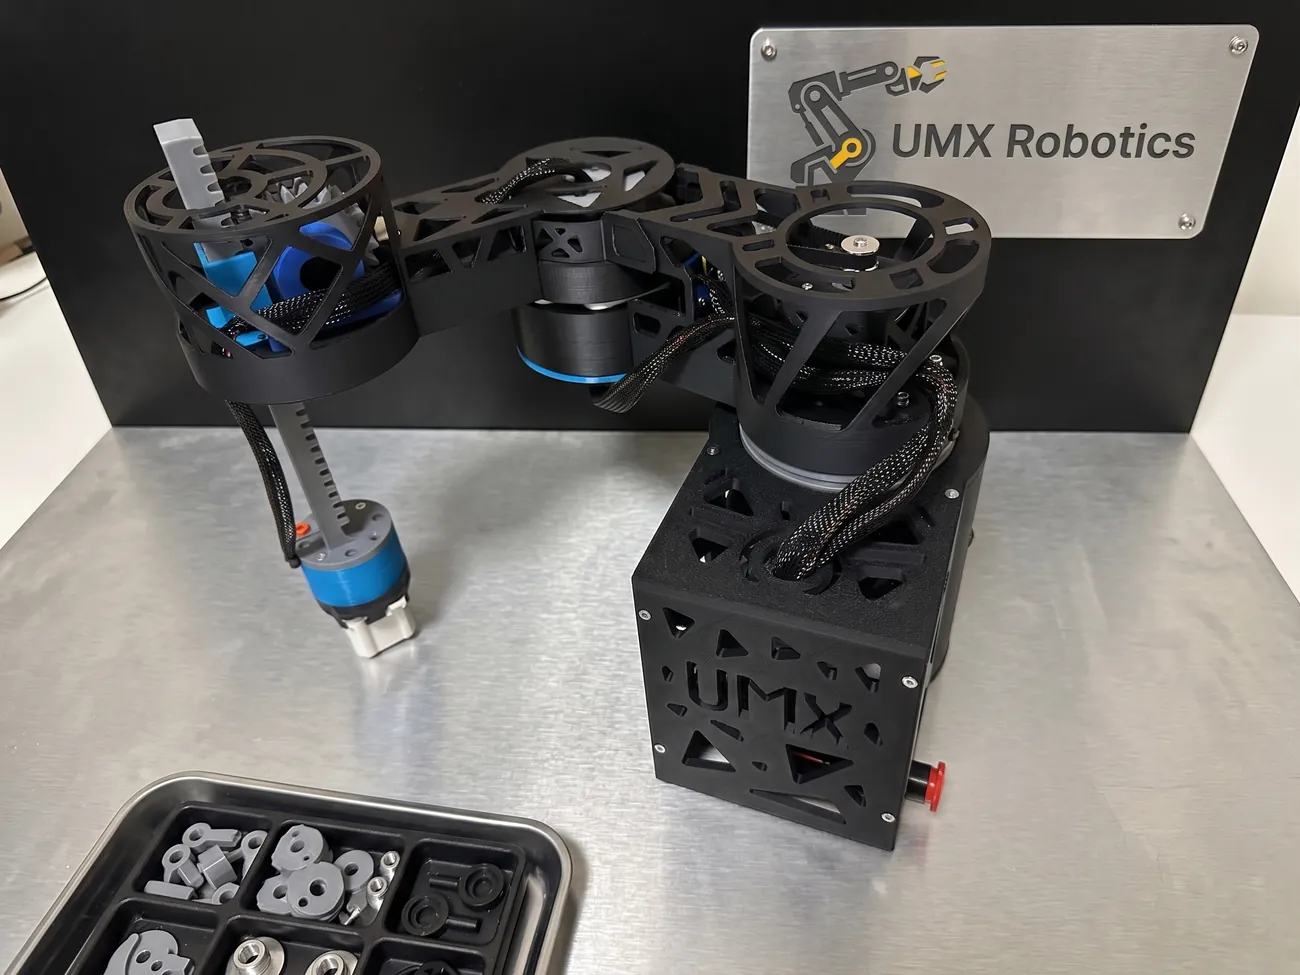
UMX Robotics · v0.1

Origin prototype

UMX Robotics · v0.1

The first proof that an affordable, 3D-printed educational robot could connect mechanics, firmware and kinematics. Everything it got wrong became the design brief for the diploma machine.

ESP323D printingKinematicsPrototype
cli-mcp-server

Open source

cli-mcp-server

A security-focused MCP server for controlled command-line operations. Command whitelisting, path-traversal protection, asynchronous timeouts. Published to PyPI.

PythonMCPSecurityPyPI
View source ↗
console-chat-gpt

Open source

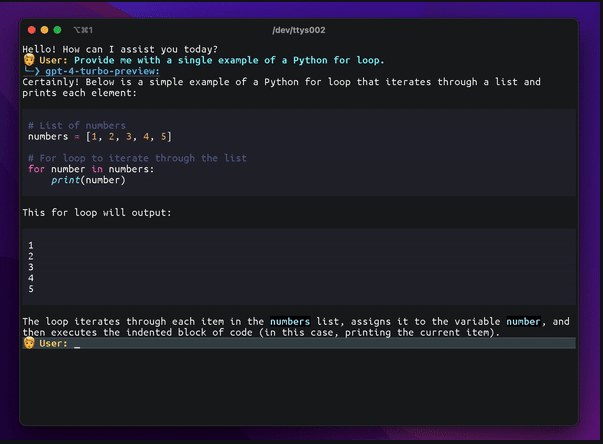
console-chat-gpt

A multi-provider command-line AI client with streaming, output transformation and MCP support across commercial and local models.

PythonCLILLMMCP
View source ↗

Smaller experiments

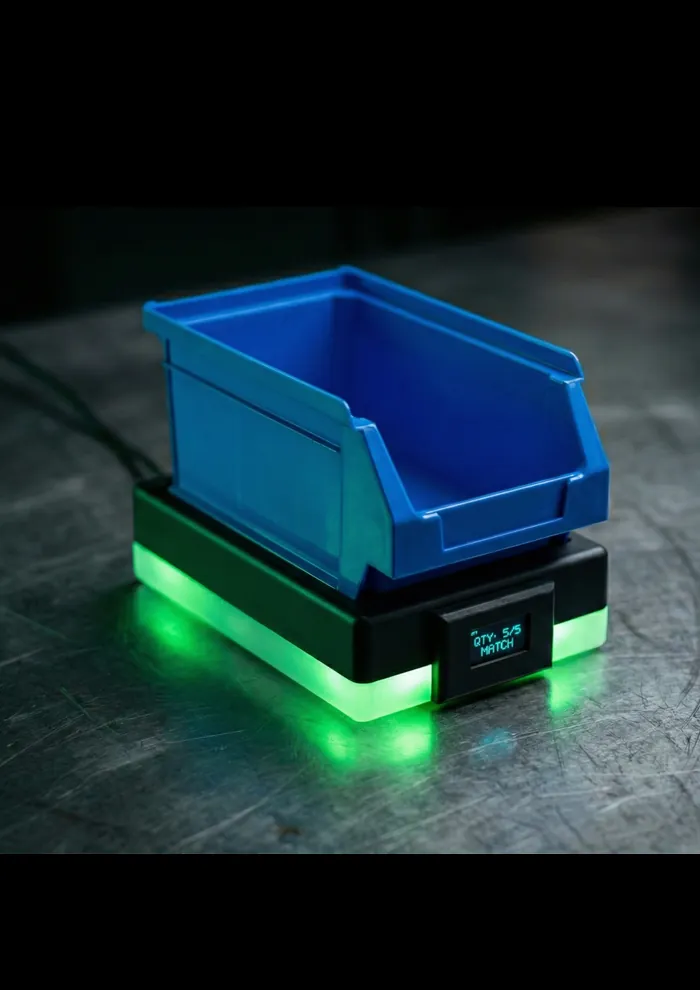
Zero-Error Assembly Node

Zero-Error Assembly Node

Industrial IoT · ESP32 · C++

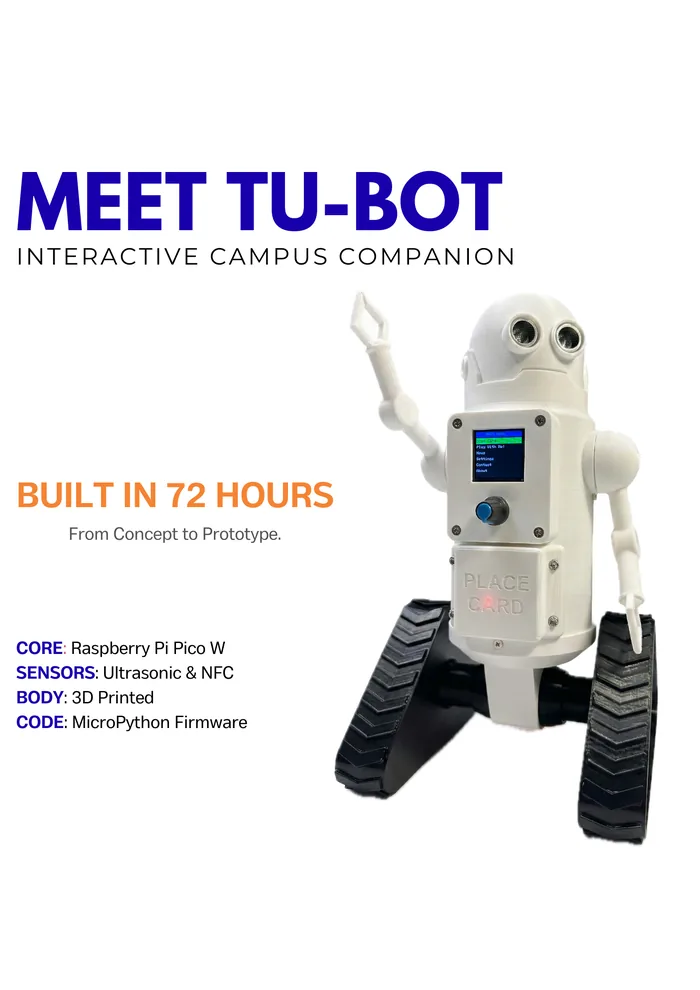
TU-Bot

TU-Bot

72-hour build · Pico · C++

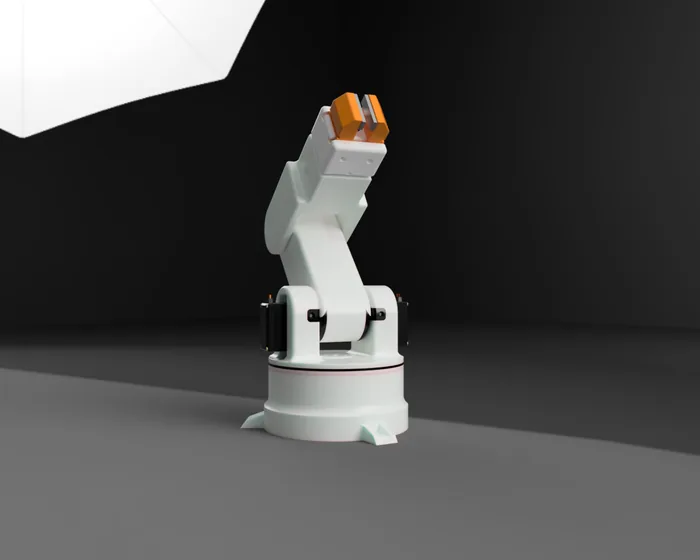
Robot Arm 4DOF

Robot Arm 4DOF

Motion control · Pico · CAD

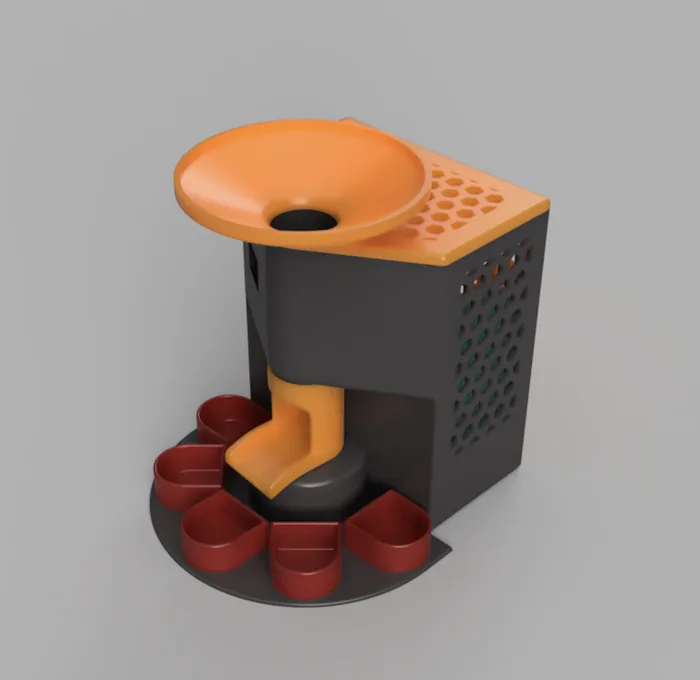
Colour Sorting

Colour Sorting

State machine · Sensors · MicroPython

Recognition / 2026

A SCARA you can
hand to a beginner

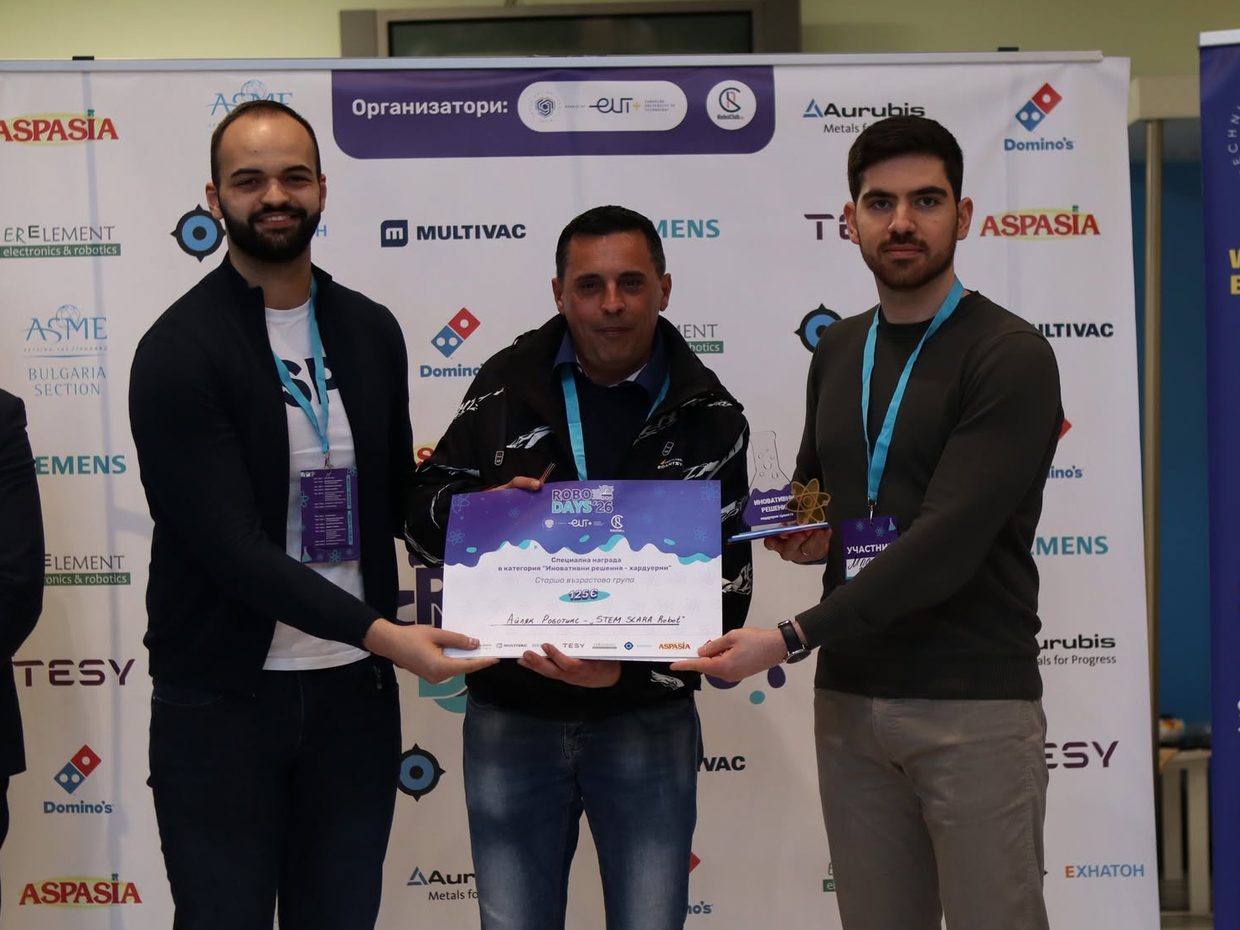
A separate machine from the diploma robot, and a deliberately cheaper one. Built with Ayliak Robotics, the robotics club at the Technical University of Sofia's Plovdiv branch: printed structure, off-the-shelf electronics, and a bill of materials kept low enough that a school could buy several. It programs from Scratch, so it works for children and for people who have never written a line of code.

  • National Robotics Days 2026RoboClub.bg special award · hardware, senior category
  • Robotics-Bulgaria.comMedia Excellence Award · Most Innovative Idea
Read the write-up ↗
The Ayliak Robotics team receiving the hardware award for the STEM SCARA Robot at National Robotics Days 2026
RoboDays '26 · STEM SCARA Robot
Mladen Uzunov
Current studies
ASEC MSc · Sofia University
Completed degree
BEng Mechatronics · TU Sofia, Plovdiv Branch
Languages
Bulgarian · English · German A1
Certification
LPIC-1

Background

From the rack
to the workbench

I started in Linux infrastructure and moved into automation and networking. Then I went back for a Mechatronics degree, because I wanted to work on the machines themselves rather than only the racks they sit in.

I'm based in Bulgaria, where I work as a network engineer and study Aerospace Engineering and Communications at Sofia University. I still enjoy getting hands-on with electronics and automation, from bringing up a board to homing an axis. Outside work and study, I hike, train, and design functional prints for whatever around the house needs fixing.

Contact

Get in touch

Infrastructure, networking, automation or robotics. Email is the fastest way to reach me.